Getting Started with Robot Vision: Math Foundations and a CS231N Learning Roadmap

A roadmap covering the essential math foundations and learning path for robot computer vision and CS231N.
This article responds to a first-year student's question by systematically mapping the mathematical knowledge needed for robot computer vision. It identifies three core pillars — linear algebra (matrix operations, SVD, coordinate transforms), calculus (chain rule, gradient descent), and probability (Bayes' theorem, Gaussian distributions, MLE) — and clarifies that CS231N's math bar is approachable with college-level coursework, while Python and NumPy fluency is often the real bottleneck. Beyond CS231N, robot vision further requires multiple view geometry, rigid body kinematics, state estimation, and SLAM. The article recommends anchoring study in linear algebra first and emphasizes the importance of pairing theory with hands-on coding practice throughout.
Why Robot Vision Demands a Solid Math Foundation
Recently, a Reddit user who had just completed their first year of software engineering posed a highly representative question: What branches of mathematics should someone study if they want to specialize in Computer Vision for Robotics? And what mathematical prerequisites are needed before diving into Stanford's renowned CS231N course?
The question sounds simple, but it cuts to the core of the AI-robotics intersection. Computer vision is fundamentally about transforming pixel data into an understanding of the world — and robot vision takes that a step further. It's not enough to "see"; the system must also drive a physical machine to act in real three-dimensional space. That means learners need both the mathematical tools of deep learning and a firm grasp of 3D geometry and motion control at a foundational level.
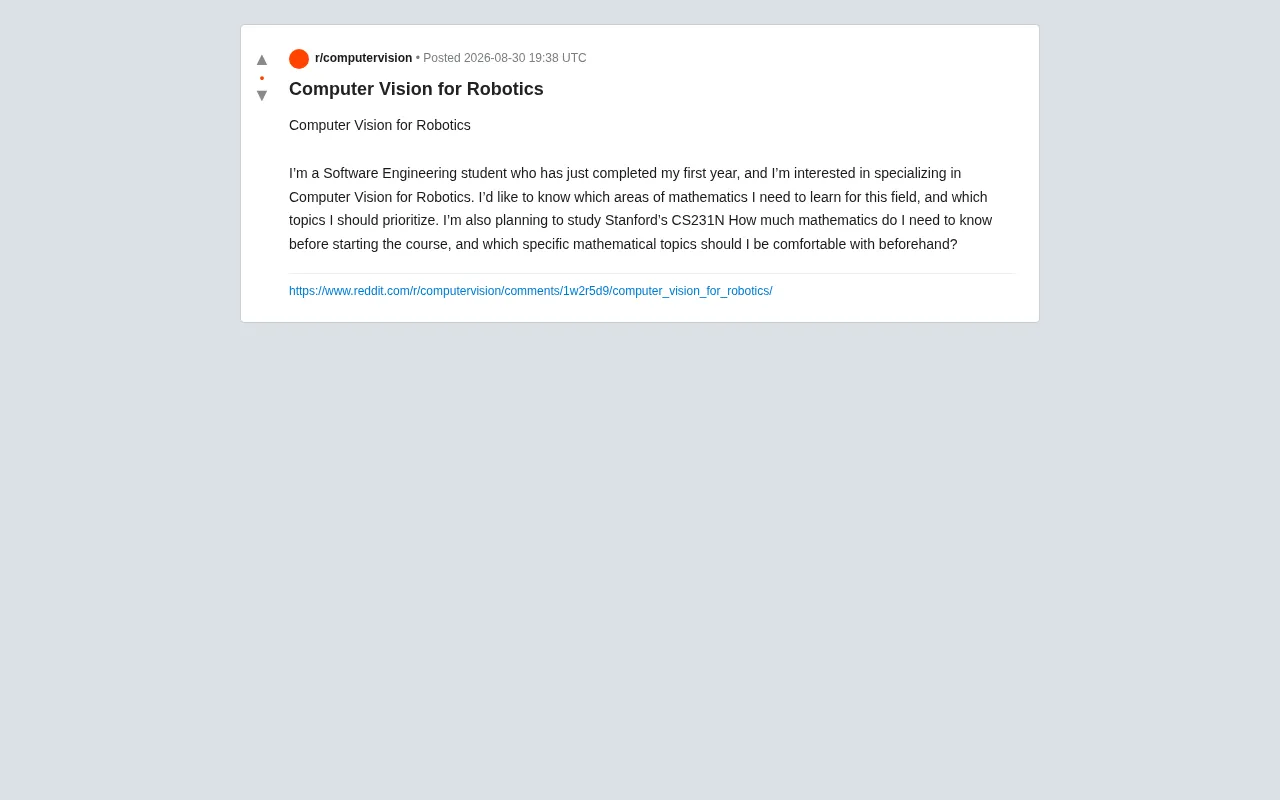
This article systematically maps out the mathematical knowledge required for robot vision and offers practical advice on preparing for CS231N.
A Full Picture of the Math Behind Robot Vision
Linear Algebra: Where Everything Begins
If you could only study one subject as your top priority, it would be linear algebra without question. Images in computer vision are essentially matrices, and virtually all neural network computations in deep learning are built on matrix multiplication and vector operations.
Specifically, learners should be comfortable with:
- Basic vector and matrix operations (addition, multiplication, transpose)
- Matrix inversion and determinants
- Eigenvalues and eigenvectors (critical for PCA dimensionality reduction and pose estimation)
- Singular Value Decomposition (SVD), a core tool in 3D reconstruction and camera calibration
- Geometric intuition behind vector spaces, bases, and linear transformations
For robot vision specifically, linear algebra carries an extra layer of importance: coordinate transformations (rotation matrices, homogeneous coordinates, rigid body transforms) are the fundamental language for describing the relative positions of cameras and robots in 3D space.
Calculus: Understanding How Models Learn
Deep learning training is fundamentally an optimization problem, and optimization cannot happen without calculus. Learners should master:
- Partial derivatives and gradients of multivariable functions
- The chain rule (the mathematical backbone of backpropagation)
- An intuitive understanding of gradient descent and its variants
- Basic optimization concepts (convex functions, local vs. global optima)
It's worth emphasizing that "backpropagation," which appears repeatedly throughout CS231N, is simply the systematic application of the chain rule across a computational graph. Without a thorough understanding of the chain rule, studying deep learning will be an uphill battle.
Probability and Statistics: Handling Uncertainty
Robots operating in the real world always face noisy, uncertain data, making probability theory an indispensable foundation for robot vision:
- Probability distributions (especially the Gaussian distribution)
- Conditional probability and Bayes' theorem
- Expectation, variance, and covariance
- Maximum likelihood estimation
In robotics, state estimation methods such as the Kalman filter and particle filter are built directly on probability theory. In deep learning, loss functions like cross-entropy also trace their roots to probability and information theory.
Preparing for CS231N Prerequisites
How Much Math Does CS231N Actually Require?
Stanford's CS231N (Convolutional Neural Networks for Visual Recognition) is the go-to introductory course for deep learning in computer vision. The good news: it does not require you to be a math expert. The course's official prerequisites primarily include:
- Basic linear algebra: Understanding matrix operations is sufficient
- Basic calculus: Familiarity with derivatives and partial derivatives
- Basic probability and statistics: Knowledge of fundamental probability concepts
- Python programming skills: This is the most practical barrier to entry
In other words, if you've already completed college-level linear algebra and calculus, you're mathematically ready to start CS231N. The area that most often needs reinforcement beforehand is proficiency with Python and NumPy, since the coursework relies heavily on vectorized programming.
Recommended Learning Order
For beginners systematically preparing for CS231N, here's a practical learning path:
- Solidify linear algebra: Gilbert Strang's MIT OpenCourseWare lectures or 3Blue1Brown's Essence of Linear Algebra video series are excellent for building geometric intuition
- Review multivariable derivatives and the chain rule from calculus
- Fill in gaps in basic probability theory
- Gain fluency in Python and NumPy: This is the most commonly overlooked yet most critical step before entering CS231N
- Begin CS231N
Leveling Up from Pure Vision to Robot Vision
Math You'll Need Beyond Vision
CS231N covers general computer vision and deep learning, but robot vision is a broader interdisciplinary field. Once the fundamentals are solid, learners need to expand in the following directions:
- Multiple View Geometry: Covers epipolar geometry, camera models, and 3D reconstruction; Hartley and Zisserman's classic textbook is the standard reference
- Rigid Body Kinematics: Rotation group SO(3), transformation group SE(3), and quaternion representations
- State Estimation and Filtering: Kalman filtering, Bayesian filtering
- Optimization Theory: Back-end optimization for problems like SLAM (Simultaneous Localization and Mapping)
These topics rarely appear in a pure vision course, yet they represent the "last mile" that lets vision algorithms actually drive a robot.
Mindset and Practical Advice
One important reminder: you don't need to finish all the math before you start building things. Deep learning and robotics are highly practice-driven fields — learning while doing is often far more effective than trying to master all the theory before touching code. Many concepts become much clearer through hands-on programming and debugging.
For a first-year student, building a strong foundation in linear algebra, calculus, and probability right now — while keeping up a programming practice — already puts you on the right track. CS231N is an excellent starting point, and the full landscape of robot vision can unfold progressively as your studies advance.
Conclusion
Robot vision stands at the fascinating frontier where AI meets the physical world. Its mathematical demands include the three pillars common to all deep learning — linear algebra, calculus, and probability — as well as the geometric and kinematic tools unique to robotics. For learners just starting out, the optimal strategy is: anchor your foundation in linear algebra first, pair it with Python practice to smoothly enter CS231N, then gradually expand toward specialized areas like multiple view geometry and state estimation. Balancing theory with hands-on practice, this path will carry beginners into the broad and exciting world of intelligent robotic perception.
Related articles

Private Key Set to 4? CA's Elementary Mistake Leaves TLS Exposed
CA eMudra set private keys to tiny values like 4, making TLS certificates brute-forceable. A Computerphile video demonstrates the full process from extracting public keys to forging certificates, and explores the fragility of the PKI trust chain.

How Gen Turns Data into Decisions with ChatGPT Work
In an OpenAI user case, business leader Gen shares how ChatGPT Work turns data into decisions: within hours of launch, teams can judge whether integrations and onboarding flows work, shifting decision iteration from hundreds of trial-and-error attempts to a fast feedback loop.

ChatGPT vs. Claude In-Depth Comparison: Strong at Coding but Weak at Research — How to Bridge the Gap?
A user considers switching from ChatGPT to Claude, finding Claude stronger at coding but shallower at research. We analyze the differences and share tips to make Claude's research deeper.