Marginally Clever Tutorial Migration: A New Home for Robot Arm Guides

Marginally Clever tutorials moved to a new domain, highlighting the Sixi 2 and 3 open-source robot arm build guides.
The Marginally Clever tutorial author announced that, due to a hosting service change, all tutorials have been migrated to the new domain marginallyclever.com/guides, with particular recommendation for the Sixi 2 and 3 robot arm build guides. The author candidly noted that the design process was full of challenges and trial and error, using the metaphor of "eggs you have to break to make an omelet" to emphasize the value of iteration and failure in hardware development. The post did not elaborate on specific technical parameters but noted that the guides are suitable for enthusiasts interested in robot arms and specially thanked the community for its support—open-source hardware is not cheap, and it is users' generous help that keeps creation going. The migrated pages are categorized by project with a clear structure for easy navigation, and the author hinted that new content will continue to be released.
Tutorial Migration Announcement: New Links and Core Content
The tutorial author from the well-known maker community Marginally Clever recently announced that all tutorials have been migrated to a new domain, accessible at marginallyclever.com/guides. According to the original Reddit post, the author moved the tutorials due to a change in hosting services and particularly recommended the build guides for the Sixi 2 and 3 robot arms.
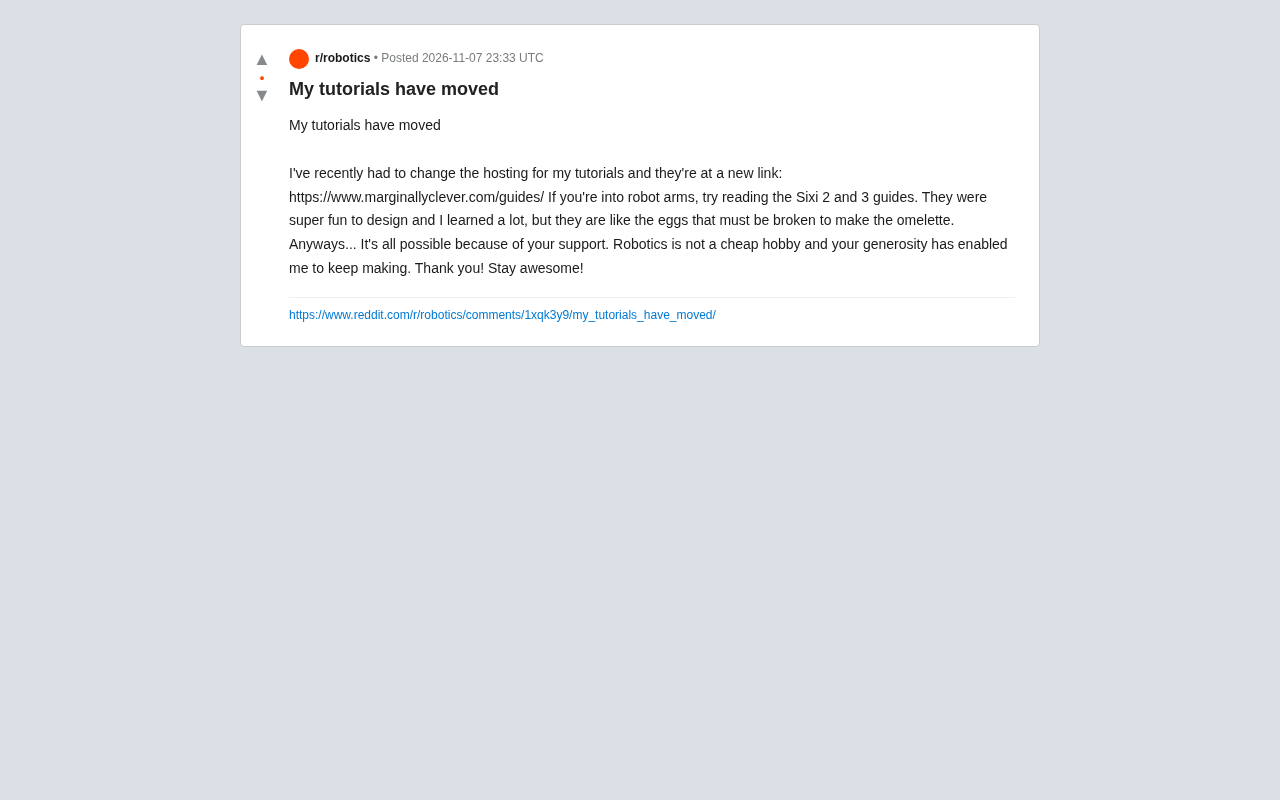
The author candidly admitted in the post that designing these robot arms was "super fun," but also acknowledged they were like "eggs you have to break to make an omelet"—meaning the process was full of challenges and trial and error. Although no specific technical details were disclosed, the author emphasized that it was community support that kept these projects going.
Sixi Robot Arms: The Story Behind the Design
The Sixi series is Marginally Clever's flagship open-source robot arm project. The author mentioned that the guides for Sixi 2 and 3 are the key recommended content of this migration, suitable for enthusiasts interested in robot arms. Although the post did not elaborate on technical specifications, the author revealed that the design process "taught me a lot," suggesting the guides may contain lessons learned from failures to successes.
For makers, the value of such tutorials lies not only in step-by-step instructions but also in presenting the real design iteration process. The author's comparison of the project to "eggs for an omelet" vividly conveys the inevitable setbacks and breakthroughs in hardware development.
Sixi is an open-source six-axis desktop robot arm developed by Marginally Clever, its name a play on "six," referring to six degrees of freedom. The project adopts a modular design, with hardware drawings, control firmware, and host software all released under open-source licenses, allowing users to 3D print structural parts and purchase stepper motors and servos for assembly. Sixi 2 and Sixi 3 are two successive iterations of the series; the former focuses on improving structural rigidity and repeat positioning accuracy, while the latter further optimizes cable routing, joint limits, and drive solutions. The typical tech stack for open-source robot arms includes inverse kinematics solving, closed-loop stepper motor control, and control protocols based on serial or network communication. These contents are usually gradually unfolded in the build guides, so the guides have high reference value for learning robot motion control.
Community Support: The Inexhaustible Driving Force of Open-Source Hardware
At the end of the post, the author specially thanked the community for its support, stating frankly that "robot hobbies are not cheap," and that users' generous help enabled continued creation. This reflects the common crowdfunding and community mutual aid model in the open-source hardware field—makers gain feedback and resources by sharing knowledge, forming a virtuous cycle.
The migrated tutorial pages are clearly structured and categorized by project, making it easy for users to find what they need. Although the post did not mention specific update plans, the author said to "stay awesome," hinting that new content may continue to be released in the future.
Community mutual aid in the open-source hardware field is usually realized through multiple channels: code and design files are hosted on platforms like GitHub, discussions take place on Discord, Reddit, or official forums, and some projects also obtain ongoing funding through subscription-based crowdfunding on Patreon, Ko-fi, etc. Unlike open-source software, hardware projects also involve bills of materials, PCB prototyping, and 3D printing costs, so community support often includes financial donations, group purchases of parts, and testing feedback. The tutorial migration by Marginally Clever also reflects this ecosystem characteristic—the author relies on community resources to keep the project running, while the community obtains reproducible design solutions through the tutorials, forming a cycle of knowledge sharing and resource feedback.
How to Access the New Tutorials
Users can directly visit marginallyclever.com/guides to browse all tutorials. It is recommended to start with the Sixi 2 and 3 guides, especially suitable for enthusiasts with some robotics background. If you encounter link issues, you can refer to the discussion section of the original Reddit post for help.
This migration reminds us that the sustainability of open-source projects depends on the community ecosystem. Following the author's latest updates may allow you to be the first to learn about new tutorial releases.
Related articles
 Tech Frontiers
MuJoCo: An Analysis of DeepMind's Open-Source General-Purpose Physics Simulator
An in-depth analysis of Google DeepMind's open-source physics simulator MuJoCo: high-performance C++ kernel, MJCF modeling format, contact solving principles, MJX GPU acceleration, and robot reinforcement learning use cases.
 Tech Frontiers
Claude API Quick Start: The Official Quickstarts Project Collection
Anthropic's official claude-quickstarts project collection helps developers quickly build deployable apps with the Claude API. Nearly 20k stars, Python-based, great for beginners and prototyping.
 Tech Frontiers
AI Agents Connecting Directly to APIs: Which Calls Can Be Safely Allowed?
AI agents can call any API, but the real challenge is deciding which calls can be safely allowed. This article analyzes allowance decisions from three dimensions—intent matching, least privilege, and controllable impact—and argues that the control layer should sit outside the agent, combined with audit traceability to build a trustworthy API call governance mechanism.